I am a PhD student at the University of Michigan, advised by Prof Dmitry Berenson.
Previously, I was an undergraduate researcher at the Robotics Research Center (RRC), IIIT-Hyderabad, supervised by Prof K. Madhava Krishna and in close collaboration with Prof Arun Singh. I spent my summer of 2025 working with Prof David Held at Carnegie Mellon University.
I am interested in working on robot learning for manipulation (or loco-manipulation). My long-term research goal is to work towards creating robust generalist loco-manipulators that can safely work with or assist humans with any tasks. I wish to create agents which can learn from their (or some other embodiment's) prior experiences to perform tasks, while also being able to adapt to new tasks (and environments) maybe with just a few demonstrations.
Updates
- Sep 2026 I started my PhD at the University of Michigan, advised by Prof Dmitry Berenson.
Reach Out
Feel free to reach out for any discussions, collaborations or just to say hi. Most of my social media handles are just "ajitsrikanth". I'm always down for an interesting conversation — be it about Robot Learning, Reinforcement Learning, Motion Planning, Foundation Models, Computer Vision, Deep Learning / ML, Computer architecture, Hardware acceleration, any cool math theorms / neat proofs, physics, tennis, cricket, most other sports, movies, anime, world domination(?), or literally anything.
Publications
Projects
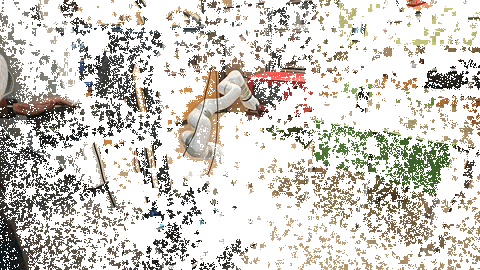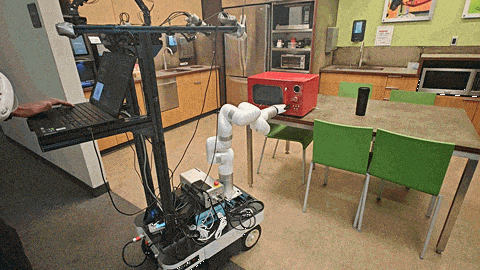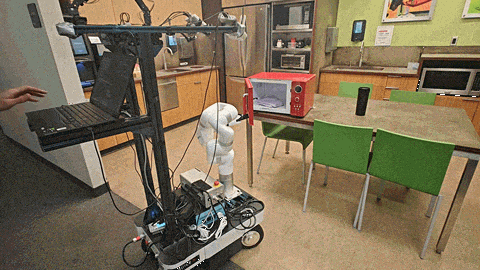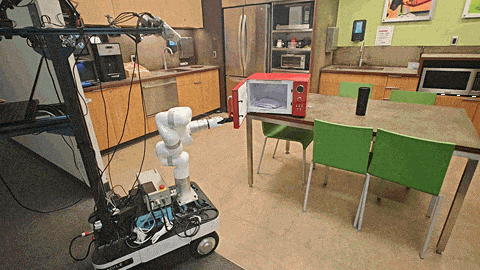
Articubot extension
- Worked on extending a zero-shot sim-to-real policy for articulated object manipulation (Articubot) by online history conditioning.
- Solved a critical real-world kinematic limitations by implementing a whole-body control maneuver, synchronizing the mobile base and XArm7’s movements, to overcome the robot’s IK limits.
- Improved real-world control by integrating compliant impedance control for safe interaction and optimizing the action execution pipeline (via parallel inference, selective action dropping, and other optimizations) to greatly speedup the real-world execution.
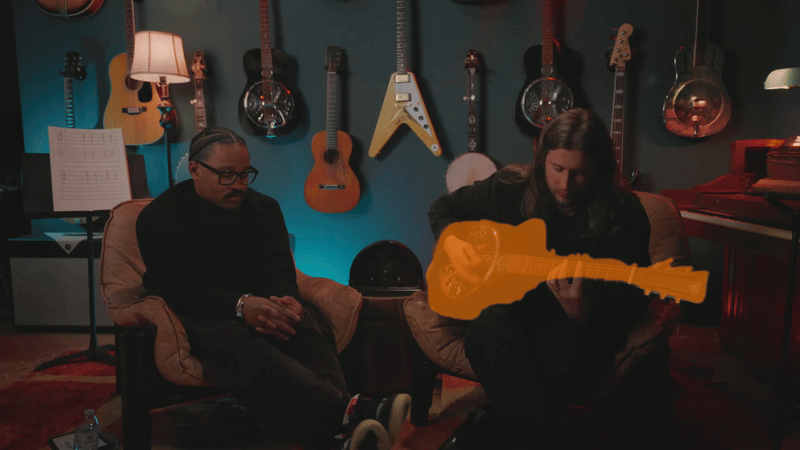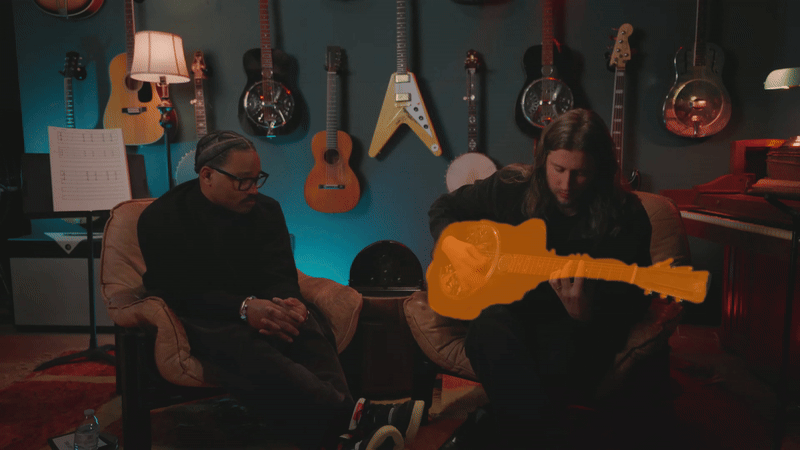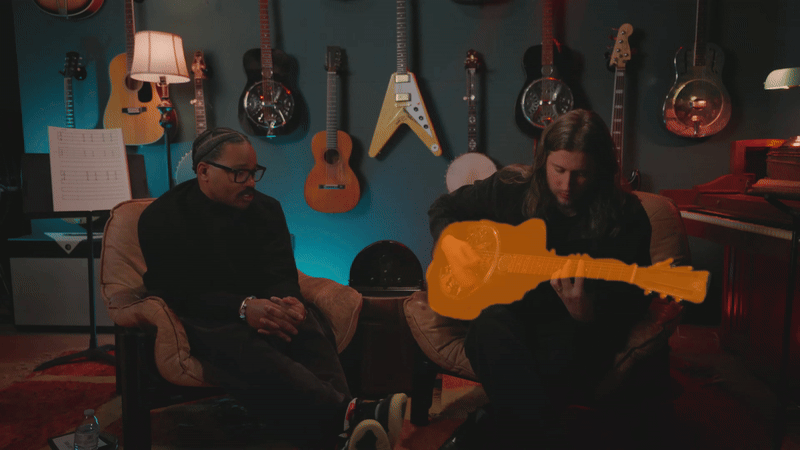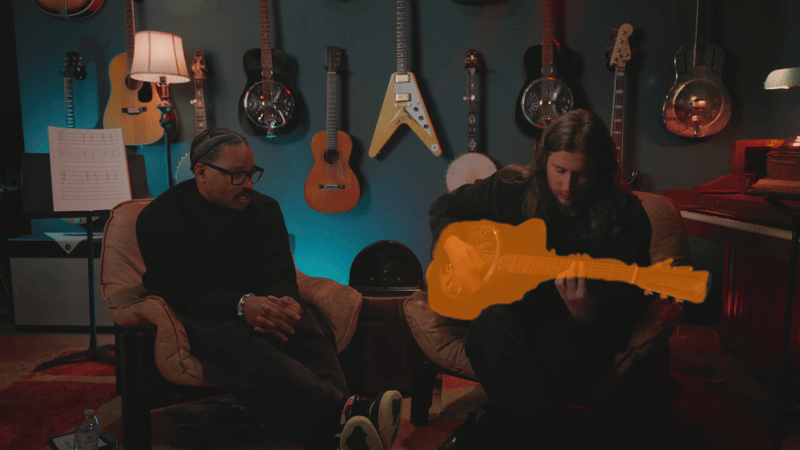
- Developed a system that combines semantic and temporal information to localize sound sources in videos
- Audio-visual grounding by aligning a large Vison-Language Model’s embeddings with audio embeddings (similar to ”Can CLIP Help Sound Source Localization?”)
- Addresses video challenges, including unidentified frames and instance disambiguation through our custom temporal module that utilizes a audio-motion transformer
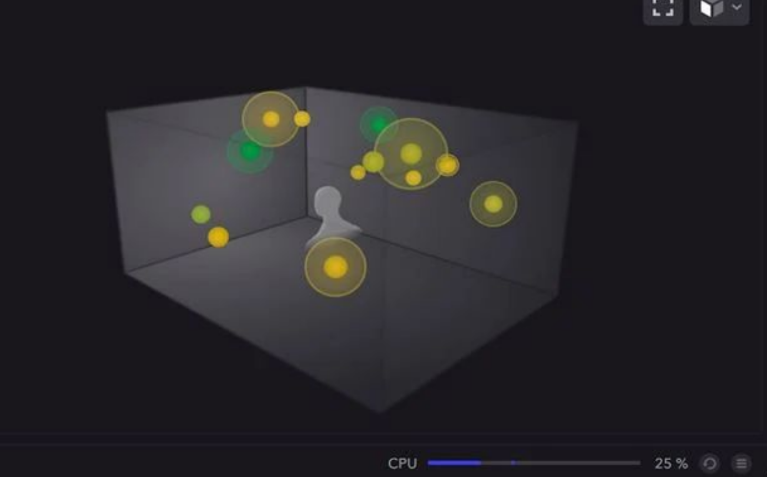
- Automatically generating spatial audio (like Dolby Atmos) for movie scenes using video understanding.
- Developed a system for complex multi-speaker environments with identity switching, and occlusions, using lightweight tracking, facial recognition and Active Speaker Detection techniques.
- Currently working on improving spatial audio generation in scenes lacking proper visual cues through advanced scene understanding.
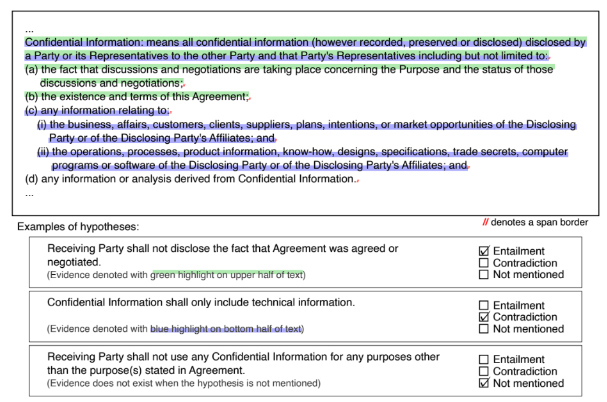
- Proposed a two-step BERT-based architecture, improving NLI and evidence inference for legal contracts.
- Improved handling of long-term dependencies in evidence-spans, and context size limits , due to our modified architecture and ensemble approach, achieving higher accuracy than the baseline ContractNLI-BERT.
Teaching
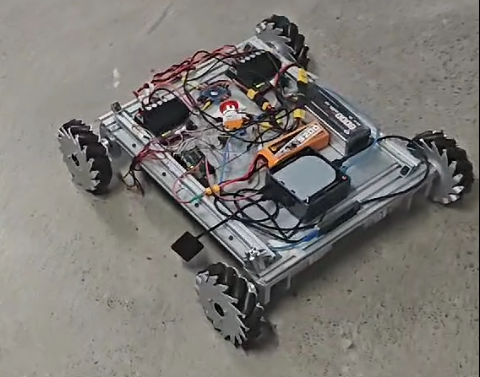
- EC4.404 Mechatronics Systems Design (Spring 2026) — Teaching Assistant at IIIT-Hyderabad.
- CS7.503 Mobile Robotics (Monsoon 2025) — Teaching Assistant at IIIT-Hyderabad.
- EC4.403 Robotics Planning and Navigation (Spring 2025) — TA by Prof. Madhava Krishna. Taught lectures on MPC/MPPI/CEM, C-space planning, Trajectory Generation, Collision Cone & Reactive Avoidance. Mentored projects across drones, manipulators, mobile robots.
- CS7.503 Mobile Robotics (Monsoon 2024) — Taught two lectures by Prof. K. Madhava Krishna on Transformations, Quaternions, and ICP SLAM.
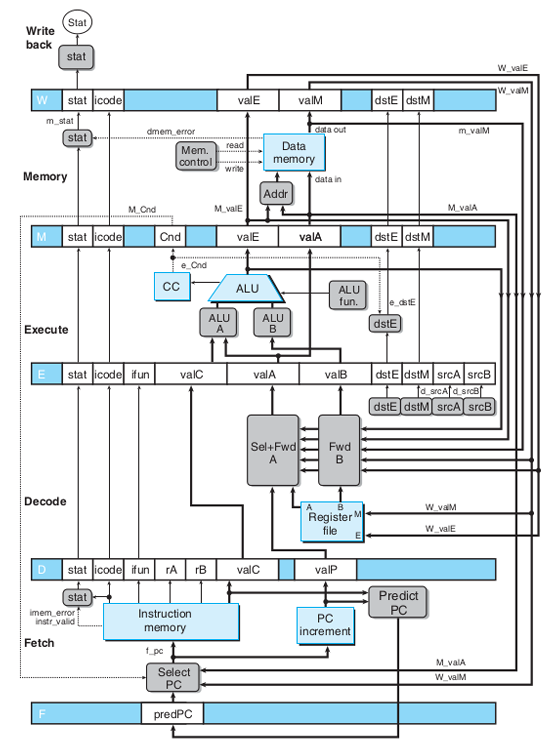
- EC2.204 Intro to Processor Architecture (Spring 2024) — TA by Prof. Deepak Gangadharan. Tutorials on Verilog HDL, X86 ISA, pipelined architectures. Designed the final project: Y86 ISA pipelined processor.
Reach Out
Feel free to reach out for any discussions, collaborations or just to say hi. Most of my social media handles are just "ajitsrikanth". I'm always down for an interesting conversation — be it about Robot Learning, Reinforcement Learning, Motion Planning, Foundation Models, Computer Vision, Deep Learning / ML, Computer architecture, Hardware acceleration, any cool math theorms / neat proofs, physics, tennis, cricket, most other sports, movies, anime, world domination(?), or literally anything.
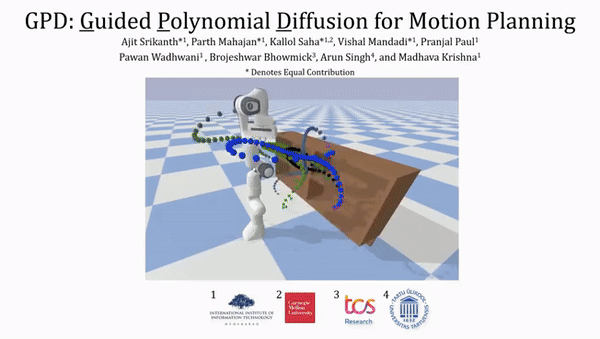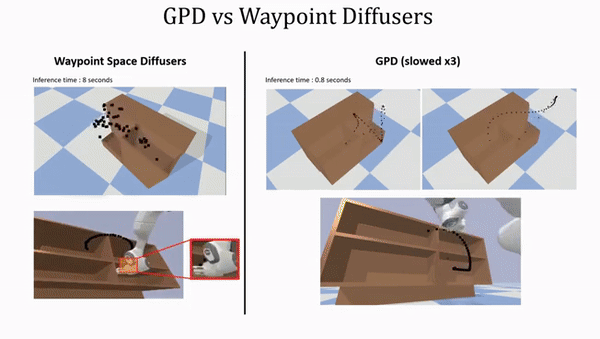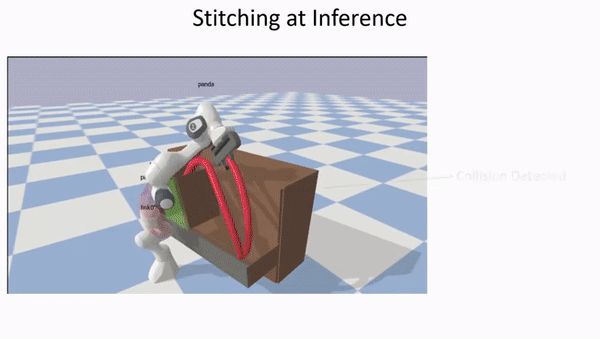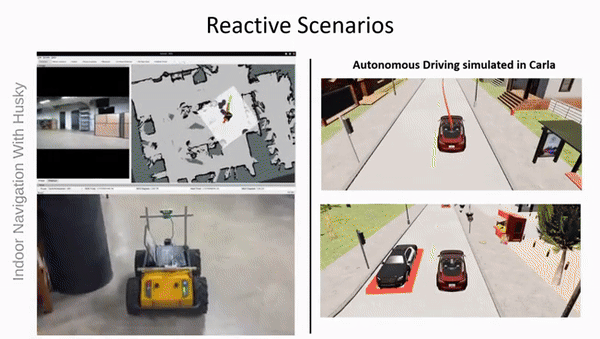
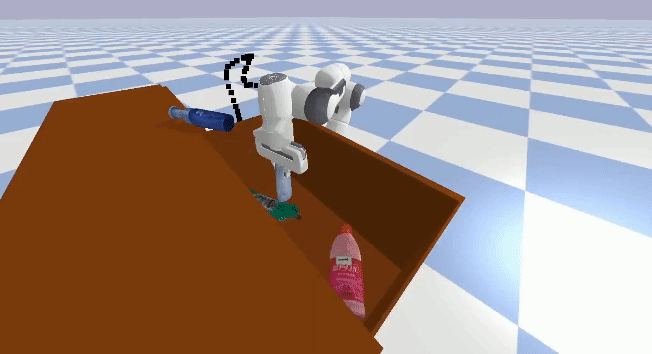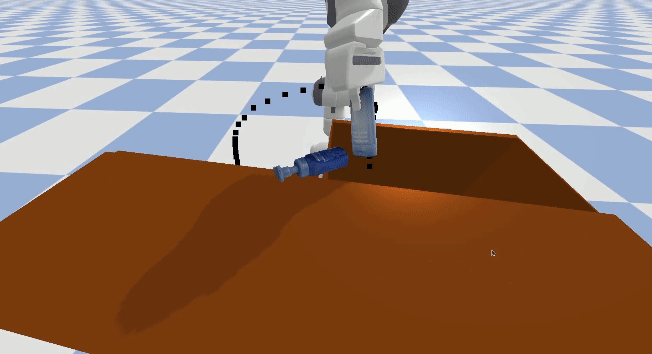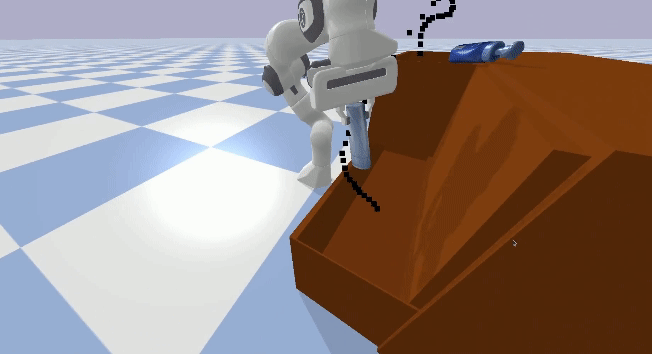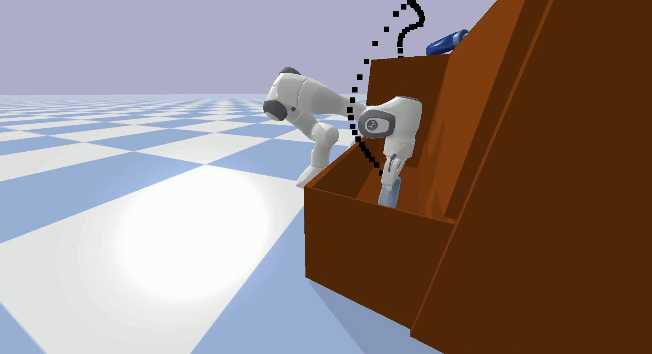
GPD: Guided Polynomial Diffusion for motion planning
We present GPD, a guided polynomial diffusion framework for robot motion planning. By parameterizing trajectories with polynomial basis functions within a diffusion model, GPD produces smooth, dynamically feasible paths with improved guidance controllability.
EDMP: Ensemble-of-costs-guided Diffusion for Motion Planning
We propose EDMP, a diffusion-based motion planning approach guided by an ensemble of cost functions. By combining multiple guidance signals during the reverse diffusion process, EDMP generates diverse, collision-free trajectories for robot motion planning in complex 3D environments.